Products

Test development electric crawler unit.

CuGo V3

Crawler Robot Development Unit

CuGo V3


Electric Crawler Unit for Prototype Development

※ Crawler unit only — control system sold separately

Build what you imagine —
Faster, cheaper, easier.

CuGo V3 packs the power of the CuGo series into a lightweight, compact body. Combining exceptional off-road capability, a maximum payload of 80 kg, and high customizability through its aluminum frame, it has been widely adopted as a prototype development platform for mobile robots, agricultural robots, and rescue robots — from research institutions to industrial applications.

80kg

Payload

3.5km/h

Max Speed

20°

Max Slope Angle

9cm

Step Clearance

5.7kg

Weight (1 unit)

IP4X

Dust Protection

Features

Features

3 Reasons Developers Choose CuGo V3

 
Step climbing and rough terrain driving

FEATURE 01

Compact Body, Outstanding Terrain Performance

Light enough to carry with one hand (5.7 kg/unit), yet stable on farmland, rubble, sand, and slopes. Clears steps up to 9 cm and climbs grades up to 20°.

9cm

Step Clearance

20°

Max Slope

5.7kg

Weight/unit

Max payload 80 kg

FEATURE 02

Up to 80 kg Payload Capacity

Despite its compact size, two units linked together support up to 80 kg. Proven as a development base for agricultural transport robots and heavy sensor-laden experimental platforms.

80kg

Max Payload

2unit

Linked Config

High customizability with aluminum frame

FEATURE 03

Highly Expandable & Customizable

Standard aluminum extrusion frame lets you reconfigure freely. Swap frames and motors to match your research goals or sensor layout. Use any ESC for control — autonomous operation with ArduPilot-compatible flight controllers has also been demonstrated.

Raspberry Pi Arduino ArduPilot

Case Studies

Real-World Applications


Adopted across diverse fields — from universities and technical colleges to independent developers.

Driving CuGo V3 with ELRS
CASE 01 Wireless Communication / In-house

"

Long-range wireless control of CuGo V3 using drone-grade ELRS

To extend the range of a standard RC transmitter (roughly 30 m in real-world testing), we implemented ELRS — a long-range wireless protocol built for drones — together with a BetaFPV receiver and an M5Stack Atom S3. Converting CRSF signals into RC servo PWM to drive the ESC enabled long-range wireless control of the unit.

CuboRex In-house Development

CuGo V3 ELRS Wireless Conversion Test (August 2023)

Read Development Report →
ROS Development Kit – Tsukuba Challenge 2023
CASE 02 Outdoor Autonomous Navigation / In-house

"

Autonomous outdoor navigation switching between GNSS and SLAM

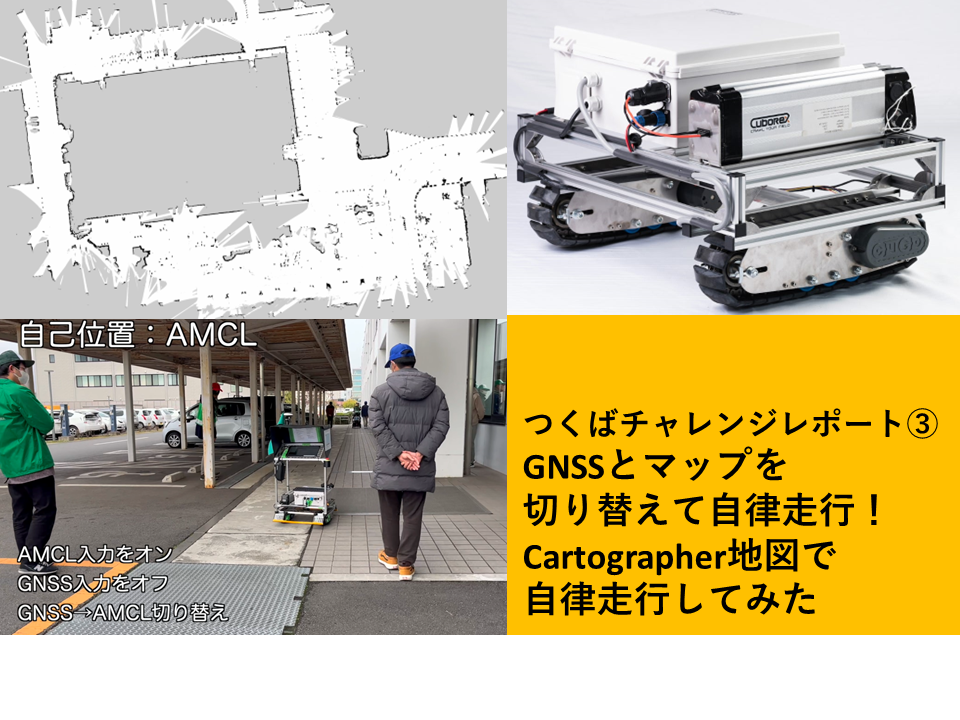
Competed in Tsukuba Challenge 2023 using a V3-based ROS development kit. Generated maps with 2D LIDAR SLAM and completed an outdoor course — including roofed areas — by switching between GNSS and AMCL localization.

CuboRex In-house Development

ROS Development Kit (V3-based) Development Report

※ This kit is no longer available for sale.
Presented as a development case using the CuGo V3 unit.

Read Development Report → YouTube① Tsukuba Challenge Run → YouTube② SLAM Mapping Demo → YouTube③ AMCL Localization Demo →
Autonomous GPR robot
CASE 03 Infrastructure Inspection / Technical College

"

Autonomous ground-penetrating radar robot for missing-person searches and infrastructure inspection

Led by Prof. Jun Sonoda. An AI-equipped robot navigates autonomously via GNSS while scanning with a ground-penetrating radar. Field trials were conducted at the Fukushima Robot Test Field, Abukuma River levee, and Katsushima municipal road as part of a Cabinet Office "Michibiki" demonstration project.

Prof. Jun Sonoda, Sendai National College of Technology

Cabinet Office Michibiki Demonstration Project (January 2024)

Citrus harvest support robot
CASE 04 Agriculture / Graduate School

"

The stable drive system on sloped farmland was the deciding factor

A camera-based system detects and follows a worker wearing red clothing, freeing both hands throughout the task. The V3's stability on sloped farmland made it the platform of choice.

Kobe University Graduate School

Citrus Harvest Support Robot Development

Read JAcom Article →
GPS autonomous robot car Aso Shirakawa R350
CASE 05 Technical College / GPS Autonomous Navigation

"

Drone technology transferred directly to a ground robot

Equipped with APM 2.6 / ArduPilot, the robot completed a 7-waypoint mission over 5 laps using standalone GPS. Drone expertise was repurposed for ground robotics in a short development cycle.

Kumamoto National College of Technology

Autonomous Robot Car "Aso Shirakawa R350" Development

Watch YouTube Demo →
MIRS program standard platform adoption
CASE 06 Technical College Education

"

Selected as the new standard platform for a 30-year robotics education program

Enables real experiments on indoor and outdoor steps and uneven terrain. Chosen as the 5th-generation standard platform for the MIRS program, thanks to its flexible integration with Raspberry Pi and Arduino.

Numazu National College of Technology, Dept. of Electronic Control Engineering

Adopted as MIRS Program Standard Platform (FY2024–)

Read Research Report (PDF) →
Autonomous agricultural spraying robot
CASE 07 Agriculture / Technical College

"

CuGo was invaluable for getting a prototype up and running fast

Developed an autonomous robot to automate herbicide spraying. The platform enabled rapid prototyping, and scaling from remote control to full autonomy was straightforward.

Sendai National College of Technology / Student Project

Autonomous Agricultural Spraying Robot Development

Read JAcom Article →
Custom omni-crawler
CASE 08 Independent Developer

"

The track was easy to modify — I could mount custom rollers right away

Used four V3 units to build an original "omni-crawler." The result is an omnidirectional crawler that slides forward, backward, and sideways without changing orientation, while still clearing steps.

Independent Developer (Mr. Kosaku)

Custom Omni-Crawler Development

Learn More →
Grape transport robot TANG
CASE 09 Agriculture / Independent Developer

"

The 80 kg payload and off-road capability made agricultural robot development a reality

Developed TANG, a grape transport robot for a Yamanashi orchard. A depth camera enables automatic worker-following, eliminating heavy lifting entirely. The compact form factor suited for narrow farm paths was key.

Two Young Engineers

Grape Transport Robot "TANG" Development

Learn More →

← Scroll horizontally to see more →

Specifications

Specifications

Product Specifications


Dimensions & Performance

Dimensions (1 unit) W169×D434×H133mm
Weight (1 unit) 5.7 kg
Payload Capacity 80 kg (2 units linked)
Max Speed 3.5 km/h
Max Slope Angle 20°
Step Clearance 9 cm
Dust / Water Protection IP4X equivalent

System & Interface

Motor Output Rated 45W
Motor Type Brushed DC Motor
Encoder Not included
ESC Not included
ROS 2 Support Not supported
※ Consider the V4 platform instead

📦 Package Contents

CuGo V3 Crawler Unit × 2
※ Units only — does not operate on its own

Brushed DC motor (no encoder) / Rated 45W

⚠️ This product cannot operate as an RC vehicle on its own

The following components are required separately for operation:

Battery ESC (Speed Controller) Controller (RC transmitter, etc.)

Which one fits you?

V3 or V4 — Which Should You Choose?


"What's the difference from V4?" is a common question. The right choice depends on your goals, budget, and development stage.

 
CuGo V3 Crawler Unit
CuGo V4 Development Platform
Best for
Drive system only Build your own control system
Start developing immediately Focus on software & algorithms
ROS 2
Not supported
✓ Supported
Encoder
Not included
✓ Included
Control Interface
Brushed DC Motor Use any ESC of your choice
UART / USB Direct connection to PC / SBC
Dust / Water Protection
IP4X equiv.
IP65 equiv.
Ideal use cases
Prototype & PoC
RC / radio-control dev
GPS autonomous navigation
Mobile robot research
Autonomous mobile robots
SLAM & navigation
ROS 2 app development
Outdoor field experiments

Choose V3 if…

"I just want the drive system to build a PoC or prototype fast"

Control it with any ESC, and plug in existing systems like RC transmitters or ArduPilot. The ideal choice when you want to keep prototype and PoC costs and timelines lean.

Choose V4 if…

"I want to get a ROS 2 autonomous robot running right away"

If you need encoder feedback and ROS 2 support, or want to focus on SLAM and navigation development, V4 is the right choice.

View V4 Product Page →

Price List

Purchase

Buy & Contact


Check current pricing and stock availability in our online store.

🛒 Buy the Unit in Our Online Store

Quotes & Business Inquiries

For bulk orders, contract development, or OEM inquiries, please reach out via the contact form.

Email us at

robotics@cuborex.com

Go to Contact Form →

Contact

Please use the inquiry form for consultation.

Inquiry Form